8 Stages, 40 Chapters — free and hands-on
A free, hands-on guide to building and learning with the 100% open-source reBot robotic arm. Stage 1 covers basic concepts, hardware, and equipment preparation.
This course was created and shared for free by the Seeed Studio AI Robotics team, to give robotics learners, students, job seekers, and makers a clear and systematic learning path. You are welcome to learn from it and share it with others, but unauthorized copying, commercial redistribution, or misuse of the content is prohibited — the copyright belongs to Seeed Studio (Shenzhen) Co., Ltd.
It is built around reBot, a 100% open-source, commercially usable and reproducible robotic arm, and combines theory with hands-on practice to cover robotic arm control, traditional robotics algorithms, and modern VLA-based embodied AI. The course is completely free — if you find it useful, please support the project by starring reBot-DevArm on GitHub ⭐, where the hardware drawings, BOM files, and other open-source resources are also available. Experienced users can go straight to our Robotics Wiki for tutorials and examples. The focus is practical understanding rather than deep mathematical derivation, so you can build a solid foundation quickly and prepare for more advanced study.
Community Groups
Discord
Course Design Principles
This course uses the reBot Arm B601-DM and B601-RS as practical platforms, combining robotic arm theory, robotics learning theory, and real hardware practice. The course outline is as follows:
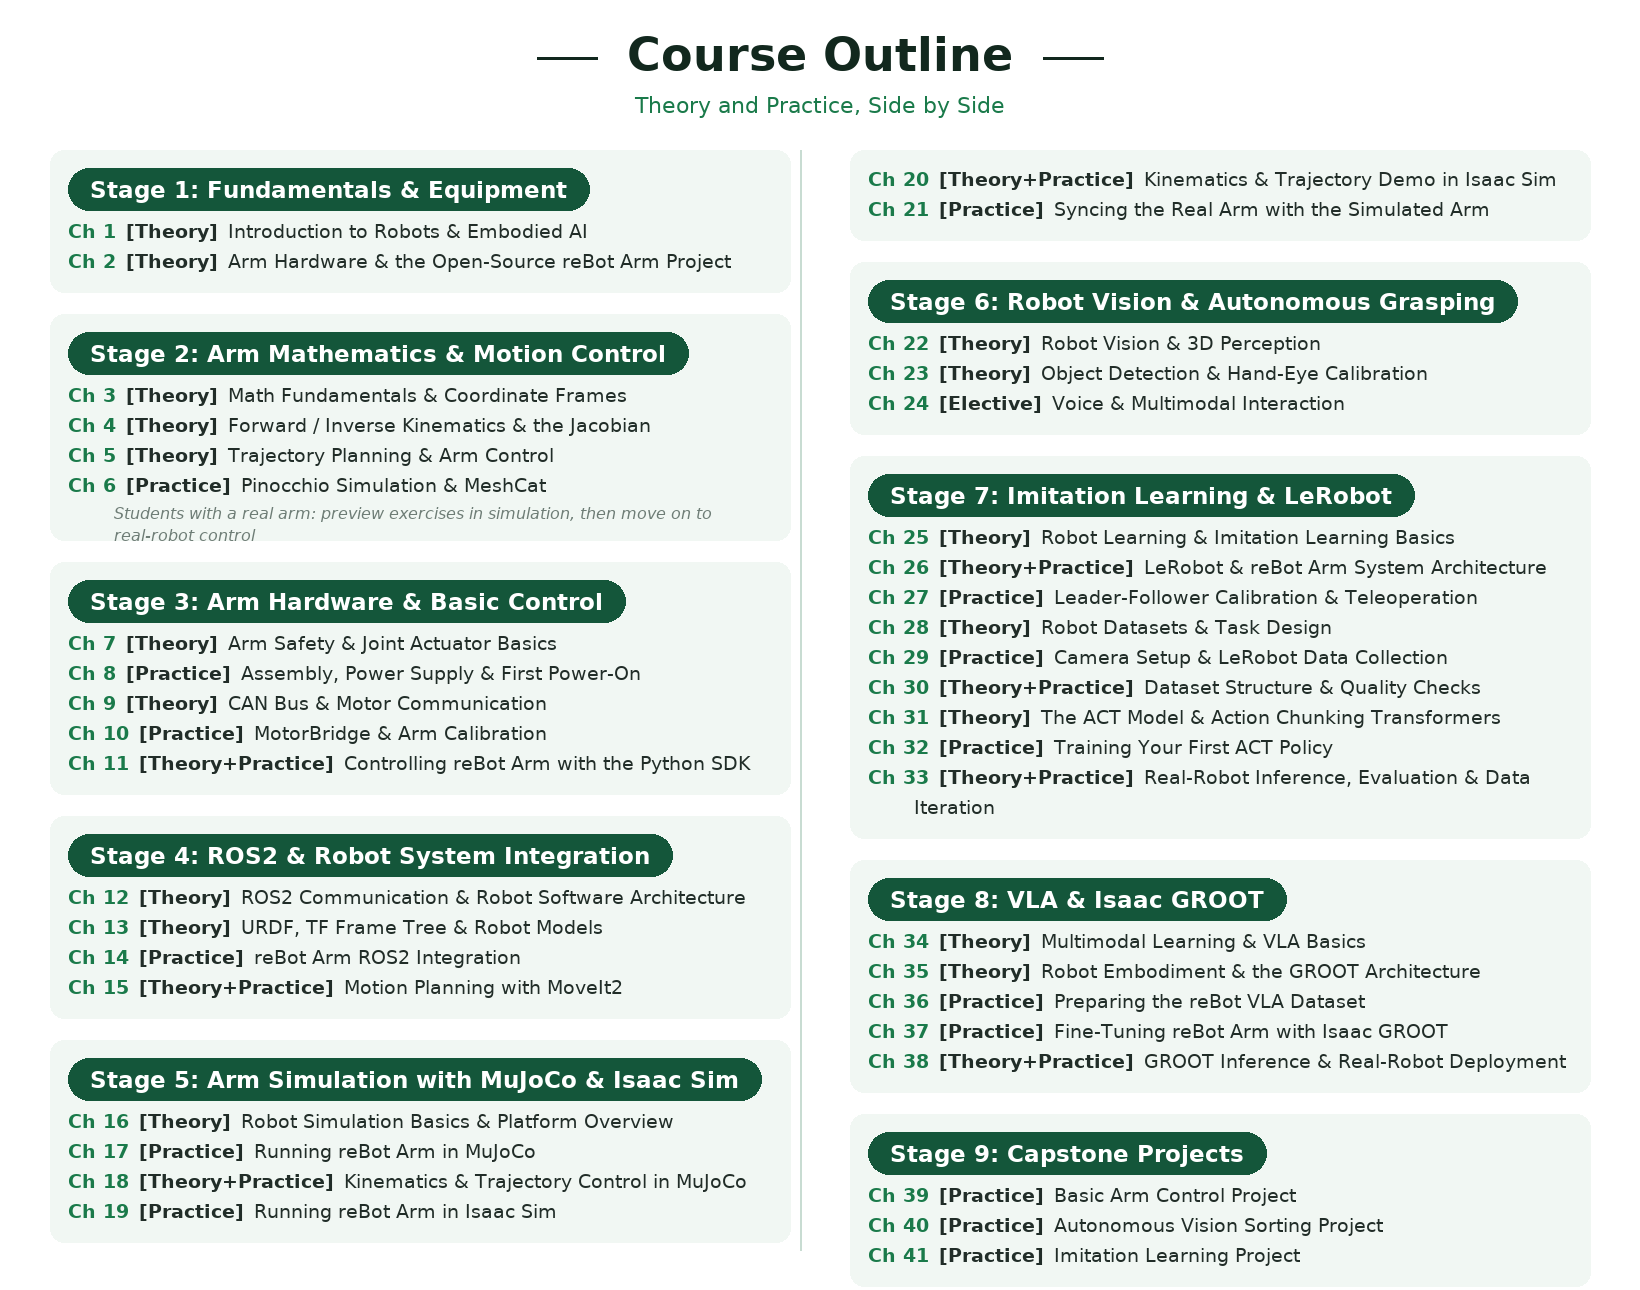
Course Structure
Stage 1: Basic Concepts and Equipment Preparation
Stage 2: Robotic Arm Assembly and Basic Control
Stage 3: Imitation Learning and LeRobot
Stage 4–8
Coming soon — the remaining stages will be added to the wiki progressively.