2. Getting to Know reBot Arm Hardware and the Open-Source Project
Chapter 2 of the Seeed Physical AI Beginner's Course — get to know the reBot Arm open-source project, the difference between the DM and RS versions, and its open-source hardware and software.
2.1 What Is reBot Arm
2.1 What Is reBot Arm
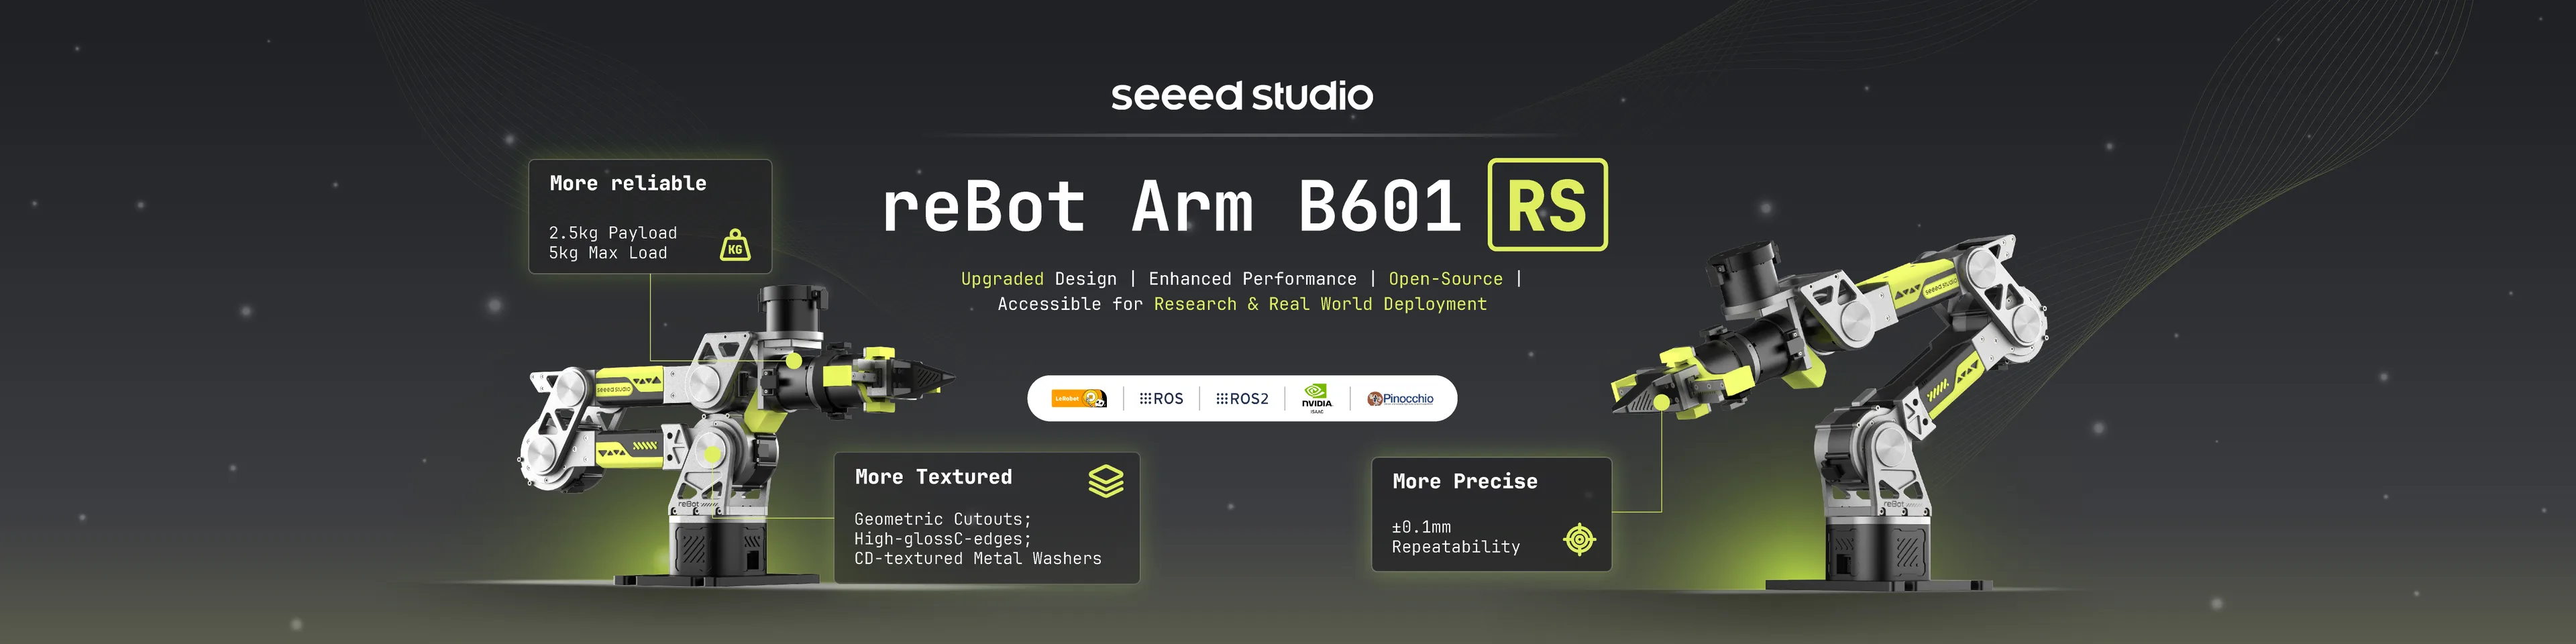
The reBot Arm B601 is a fully open-source robotic arm released by Seeed Studio, from structural hardware to software. It is an open-source desktop robotic arm for robotics education, algorithm development, and embodied intelligence research. It adopts a modular mechanical structure, provides approximately 750 mm reach and 6+1 degrees of freedom, connects to a computer via USB-CAN, and can be used for experiments such as robotic arm control, robot vision, imitation learning, and VLA.
reBot Arm is not just robotic arm hardware; it also provides complete development materials from low-level control to high-level AI applications. From this open-source project, you can learn from scratch:
- Robotic arm design and assembly (DM product detail video);
- Robotic arm calibration and joint control;
- Forward kinematics, inverse kinematics, and trajectory planning;
- Pinocchio dynamics analysis and MeshCat visualization;
- Leader–Follower master-slave teleoperation;
- LeRobot data collection, training, and evaluation; Hugging Face web page recording;
- RGB-D visual recognition and autonomous grasping;
- Isaac Sim;
- ROS2 integration and secondary development;
- Adaptation of robot policy models such as ACT and GR00T.
Its main goal is to allow users to learn and validate robotic arm and embodied intelligence algorithms using relatively low-cost, open, and modifiable hardware.
2.2 Why Design Two Versions: DM and RS
2.2 Why Design Two Versions: DM and RS
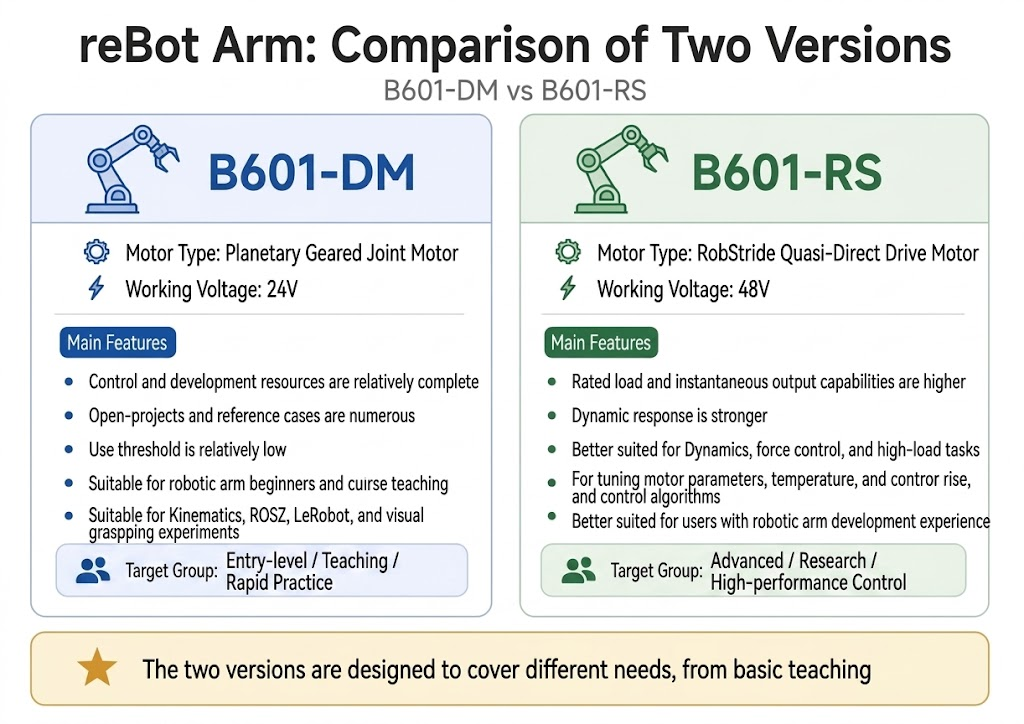
The reBot Arm B601 offers two versions:
- B601-DM
- B601-RS
Both versions use a similar mechanical structure and upper-layer software system, but use different types of joint motors.
2.3 Parameter Comparison Between reBot Arm DM and reBot Arm RS
2.3 Parameter Comparison Between reBot Arm DM and reBot Arm RS
| Product | reBot Arm DM | reBot Arm RS |
|---|---|---|
| SKU | 100065783 | 100019336 |
| Purchase Link | Bazaar | Bazaar |
| Degrees of Freedom | 6+1 | 6+1 |
| Rated Payload | 1.5 kg | 2.5 kg |
| Maximum Payload | 2.5 kg | 5 kg |
| Repeatability | 0.2 mm | 0.1 mm |
| Reach | 767 mm | 754.7 mm |
| Communication | CAN Bus via USB-CAN Adapter | CAN Bus via USB-CAN Adapter |
| Power Supply | 24V DC, 15A | 48V DC, 12.5A |
| Actuator Type | Damiao DM Planetary Gear Joint Actuators | RoboStride Quasi-Direct-Drive Joint Actuators |
2.4 Open-Source Hardware and Open-Source Software
2.4 Open-Source Hardware and Open-Source Software
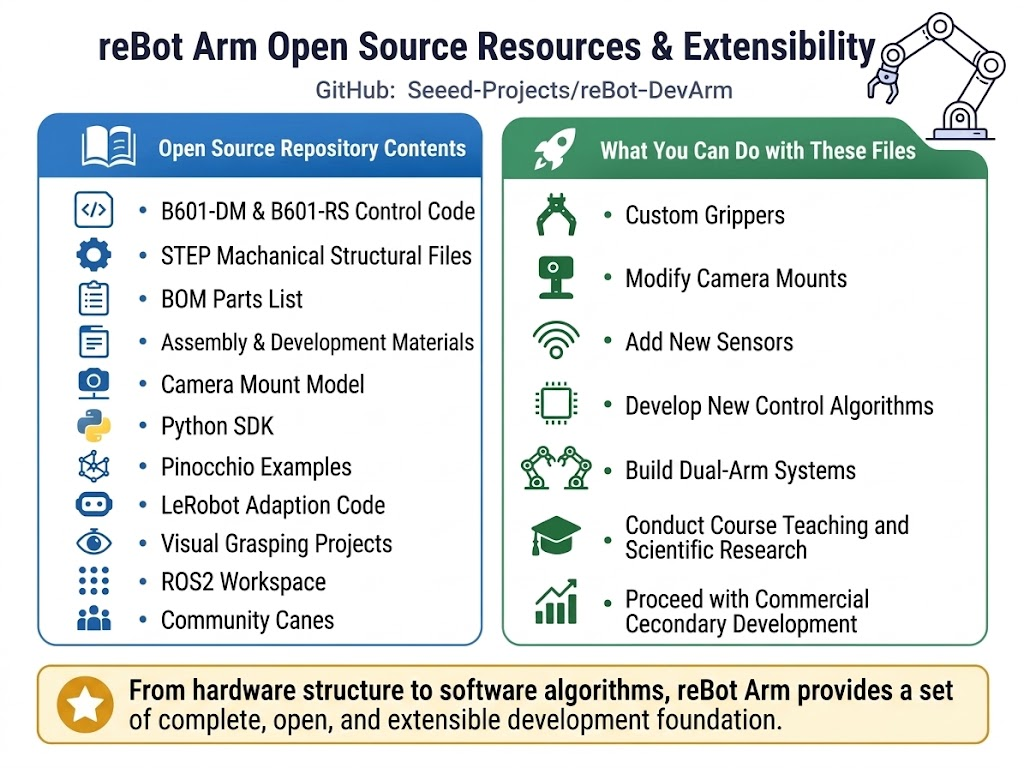
Both the hardware and software materials of reBot Arm are open to the public.
GitHub repository: https://github.com/Seeed-Projects/reBot-DevArm/