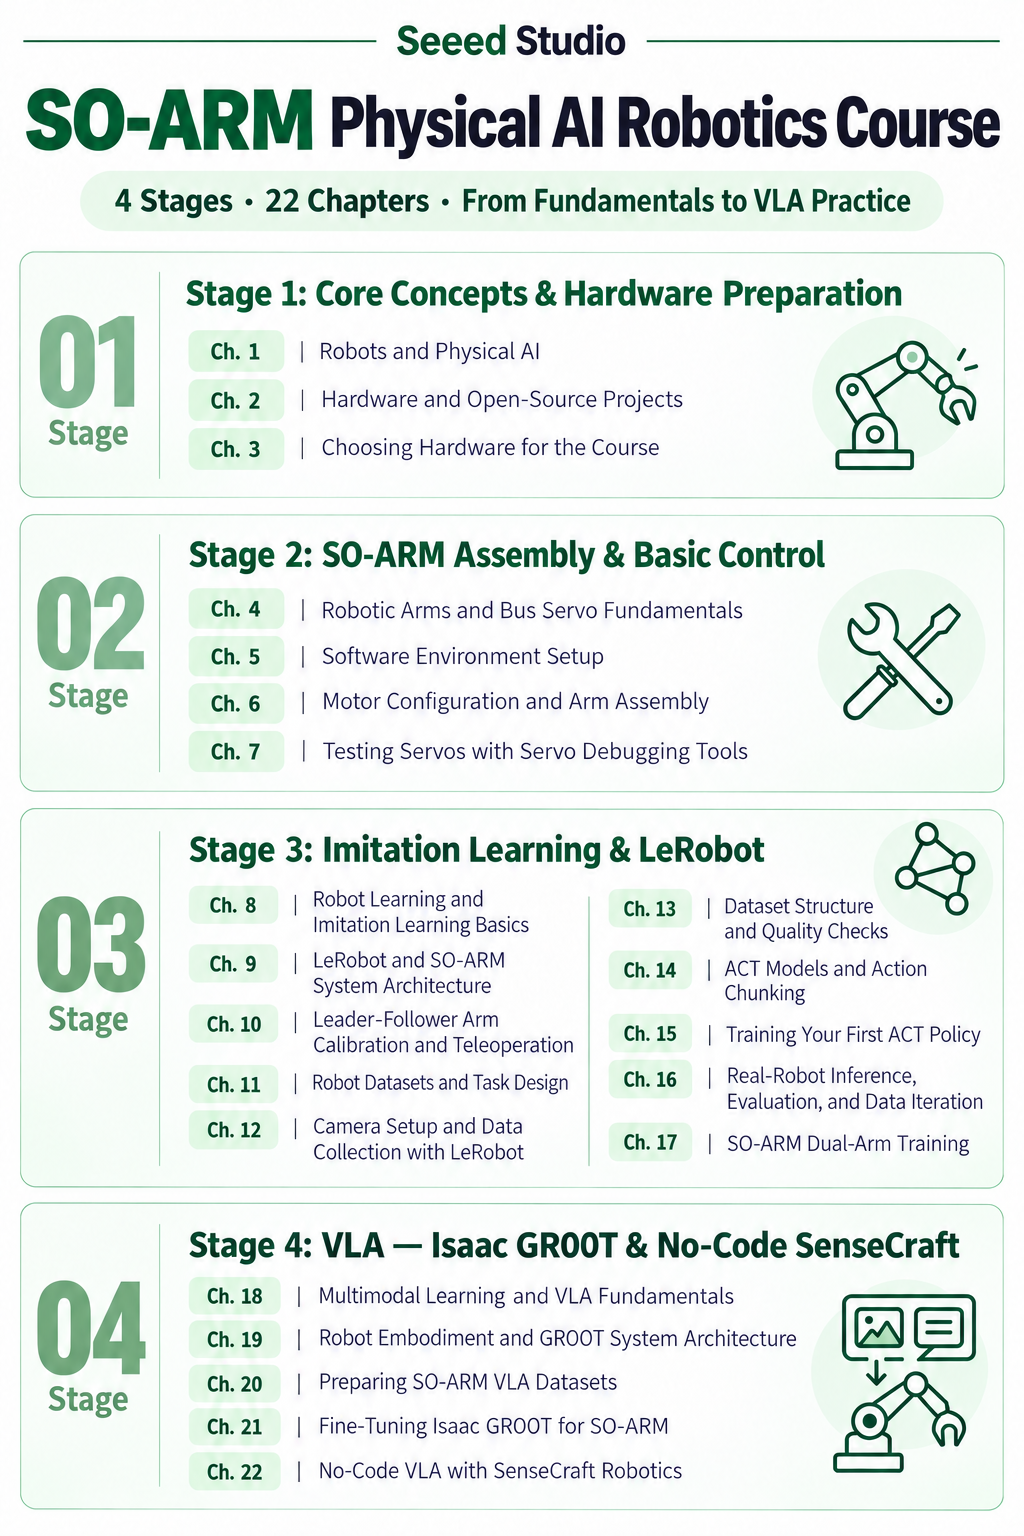
4 Stages, 22 Chapters — free and hands-on
A free, hands-on guide to building and learning with the open-source SO-ARM100 / SO-ARM101 robotic arm. The published chapters take you from basic concepts, assembly and servo control, through imitation learning with LeRobot and double-arm training, to VLA fine-tuning with Isaac GR00T — and finish with a no-code VLA path on the SenseCraft Robotics platform.
This course was created and shared for free by the Seeed Studio AI Robotics team, to give robotics learners, students, job seekers, and makers a clear and systematic learning path. You are welcome to learn from it and share it with others, but unauthorized copying, commercial redistribution, or misuse of the content is prohibited — the copyright belongs to Seeed Studio (Shenzhen) Co., Ltd.
It is built around SO-ARM100 / SO-ARM101, the open-source leader-follower robotic arm originally designed by TheRobotStudio and made into complete kits by Seeed Studio, and it combines theory with hands-on practice to cover robot arm control, the LeRobot imitation-learning ecosystem, and modern VLA-based embodied AI. The course is completely free — if you find it useful, please support the project by starring SO-ARM100 on GitHub ⭐, where the STL files and other open-source resources are also available. Experienced users can go straight to our Robotics Wiki for tutorials and examples. The focus is practical understanding rather than deep mathematical derivation, so you can build a solid foundation quickly and prepare for more advanced study. Stage 2 assembles and configures the arms step by step; Stage 3 walks the full LeRobot loop — calibration, teleoperation, datasets, ACT training, real-robot inference — and closes with an elective double-arm chapter; Stage 4 first explains VLA theory and GR00T architecture, then fine-tunes GR00T on an SO-ARM dataset, and finishes with the no-code SenseCraft Robotics path for readers without a training GPU.
Community Groups
Discord
Course Design Principles
This course uses the SO-ARM100 / SO-ARM101 leader-follower kits as practical platforms, combining robotic arm theory, robotics learning theory, and real hardware practice. The course outline is as follows: